Lattice Fusion Navstack
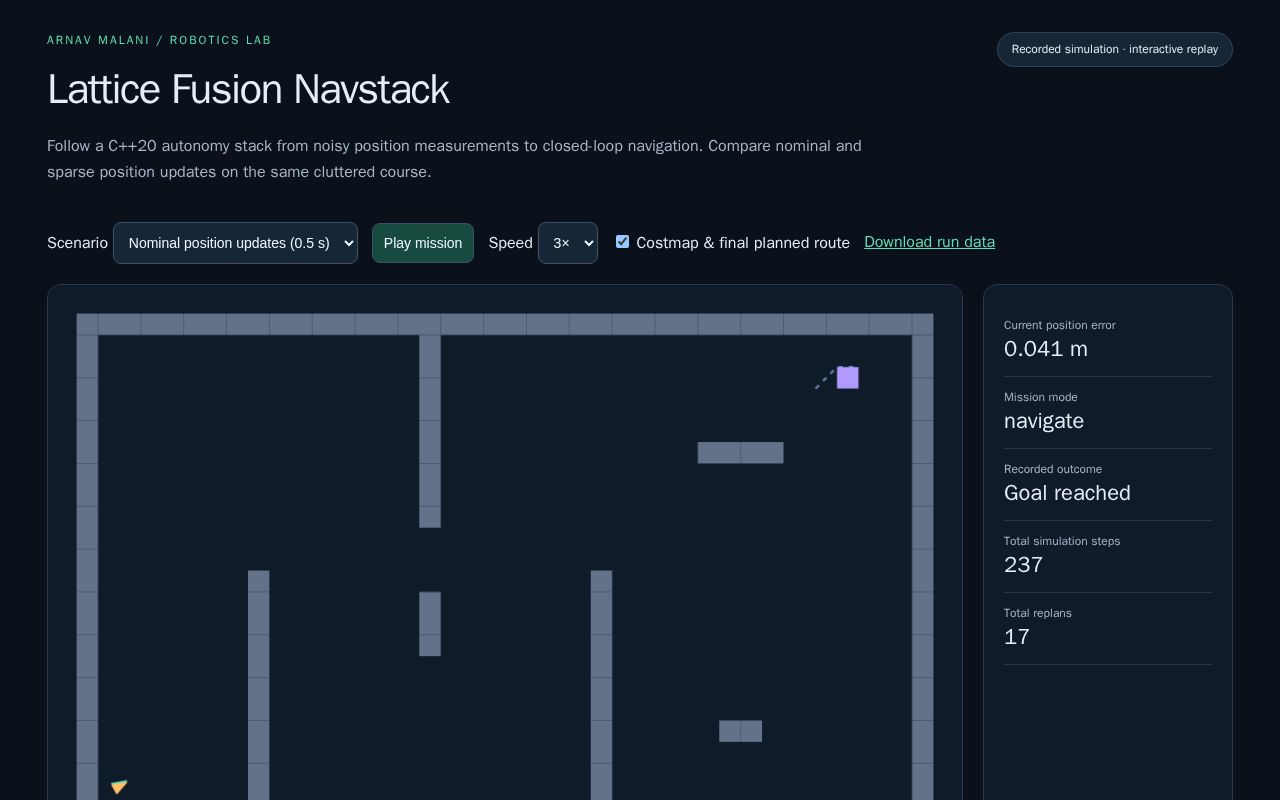
Follow a C++20 autonomy stack from noisy position measurements to closed-loop navigation. Compare nominal and sparse position updates on the same cluttered course.
Description excerpted from the original listing, which is linked below.
 BitsExplorer